Welcome to the Onshape forum! Ask questions and join in the discussions about everything Onshape.
First time visiting? Here are some places to start:- Looking for a certain topic? Check out the categories filter or use Search (upper right).
- Need support? Ask a question to our Community Support category.
- Please submit support tickets for bugs but you can request improvements in the Product Feedback category.
- Be respectful, on topic and if you see a problem, Flag it.
If you would like to contact our Community Manager personally, feel free to send a private message or an email.
How to find extent planes for a solid in a specific direction

brad_phelan
Member Posts: 91 ✭✭
I have created a feature script feature. The user can select
Before:
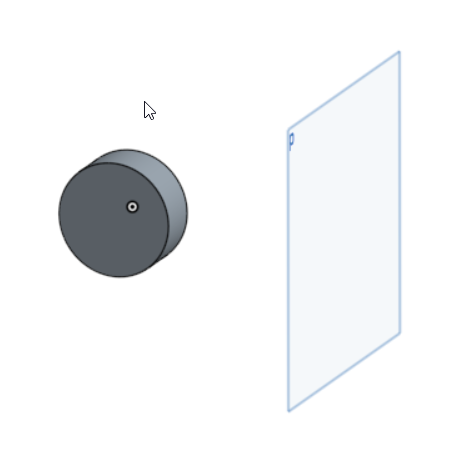
After:
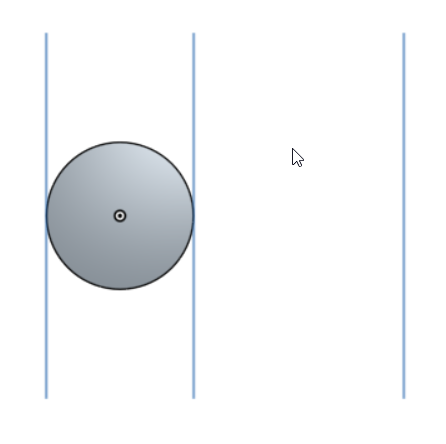
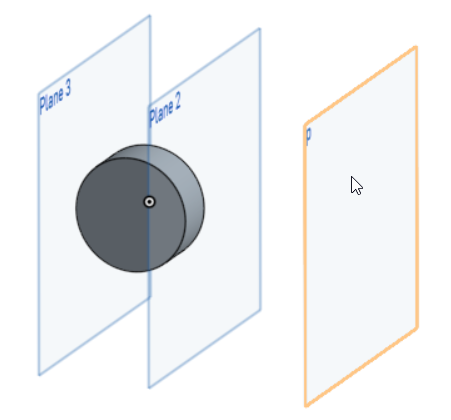
Any ideas how to do this?
- S is Solid
- P is Plane
Before:
After:
Any ideas how to do this?
Tagged:
0
Comments
-
evBox3d of solid S with
tightoption will give you 2 vectors and the direction of plane P will give you the normal, so you can construct 2 planes.
in the arbitary case you may requare to construct local CS to pass into evBox3d, as X axis could be used normal of plane P, Z vector can be obtained by perpendicularVector(xVector)
0 -
Here is a solutionFeatureScript 660;import(path : "onshape/std/geometry.fs", version : "660.0");annotation { "Feature Type Name" : "Auto Rib" }export const myFeature = defineFeature(function(context is Context, id is Id, definition is map)precondition{annotation { "Name" : "Part", "Filter" : BodyType.SOLID, "MaxNumberOfPicks" : 1 }definition.Part is Query;annotation { "Name" : "Rib Direction", "Filter" : GeometryType.PLANE, "MaxNumberOfPicks" : 1 }definition.Plane is Query;annotation { "Name" : "Number of Ribs" }isInteger(definition.myCount, POSITIVE_COUNT_BOUNDS);annotation { "Name" : "Rib Thickness" }isLength(definition.myLength, LENGTH_BOUNDS);}{const p is Plane = evPlane(context, {"face" : definition.Plane});var b is Box3d = evBox3d(context, {"topology" : definition.Part,"cSys" : coordSystem(p)});const t is Transform = toWorld(coordSystem(p));b = box3d(t * b.minCorner, t*b.maxCorner);opPoint(context, id + "minCorner", {"point" : b.minCorner});opPoint(context, id + "maxCorner", {"point" : b.maxCorner});const p0 = dummyQuery(id + "minCorner", EntityType.VERTEX);const p1 = dummyQuery(id + "maxCorner", EntityType.VERTEX);cPlane(context,id + "pl0",{ "entities" : qUnion([definition.Plane, p0]),"cplaneType" : CPlaneType.PLANE_POINT,});cPlane(context,id + "pl1",{ "entities" : qUnion([definition.Plane, p1]),"cplaneType" : CPlaneType.PLANE_POINT,});});
The test result is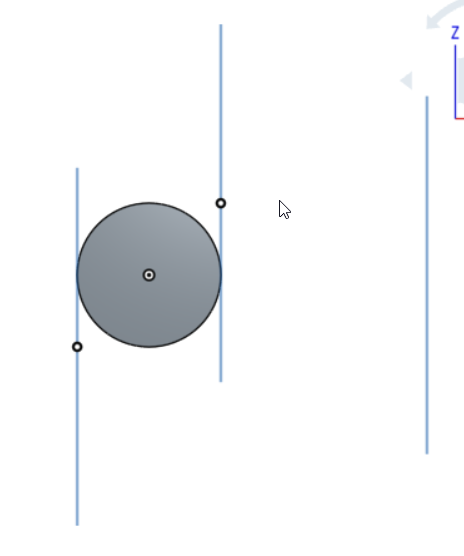
I would prefer the the planes are vertically aligned correctly but the result is not incorrect.0 -
i see here some redundant code, when you obtained "p" you can make construction planes in a fewer steps like
p = coordSystem(p);
b = evBox3d(context, {"topology" : definition.Part,"cSys" : p});
b.minCorner = toWorld(p,b.minCorner);
b.maxCorner = toWorld(p,b.maxCorner);
opPlane(context, id+"minPlane",{
"plane": plane(b.minCorner, p.zAxis),
.....
});
opPlane(context, id+"maxPlane",{
"plane": plane(b.maxCorner, p.zAxis),
.....
});
0 -
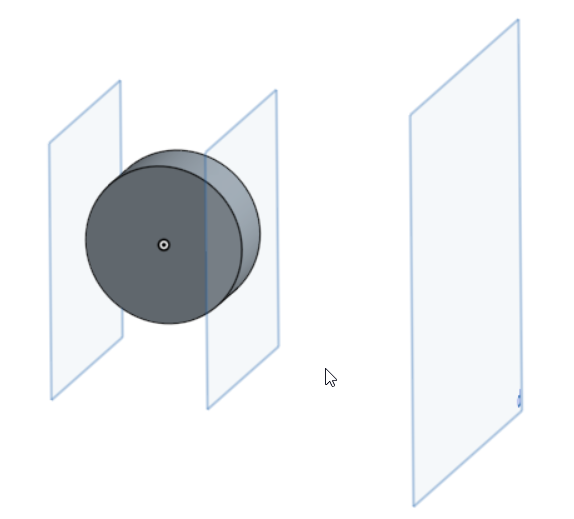
A better solution is to project the box3d corners onto the original plane vector. Then the result planes are just offset from the originalFeatureScript 660;import(path : "onshape/std/geometry.fs", version : "660.0");annotation { "Feature Type Name" : "Auto Rib" }export const myFeature = defineFeature(function(context is Context, id is Id, definition is map)precondition{annotation { "Name" : "Part", "Filter" : BodyType.SOLID, "MaxNumberOfPicks" : 1 }definition.Part is Query;annotation { "Name" : "Rib Direction", "Filter" : GeometryType.PLANE, "MaxNumberOfPicks" : 1 }definition.Plane is Query;annotation { "Name" : "Number of Ribs" }isInteger(definition.myCount, POSITIVE_COUNT_BOUNDS);annotation { "Name" : "Rib Thickness" }isLength(definition.myLength, LENGTH_BOUNDS);}{const p is Plane = evPlane(context, {"face" : definition.Plane});var b is Box3d = evBox3d(context, {"topology" : definition.Part,"cSys" : coordSystem(p)});const t is Transform = toWorld(coordSystem(p));b = box3d(t * b.minCorner, t * b.maxCorner);const line is Line = line(p.origin, p.normal);const p0 is Vector = project(line, b.minCorner);const p1 is Vector = project(line, b.maxCorner);opPoint(context, id + "p0", {"point" : p0});opPoint(context, id + "p1", {"point" : p1});const p0Id = dummyQuery(id + "p0", EntityType.VERTEX);const p1Id = dummyQuery(id + "p1", EntityType.VERTEX);cPlane(context,id + "pl0",{ "entities" : qUnion([definition.Plane, p0Id]),"cplaneType" : CPlaneType.PLANE_POINT,});cPlane(context,id + "pl1",{ "entities" : qUnion([definition.Plane, p1Id]),"cplaneType" : CPlaneType.PLANE_POINT,});});0
-
And dropping down to using opPlane instead of cPlane makes the code shorter and avoid inserting dummy points into the modelFeatureScript 660;import(path : "onshape/std/geometry.fs", version : "660.0");annotation { "Feature Type Name" : "Auto Rib" }export const myFeature = defineFeature(function(context is Context, id is Id, definition is map)precondition{annotation { "Name" : "Part", "Filter" : BodyType.SOLID, "MaxNumberOfPicks" : 1 }definition.Part is Query;annotation { "Name" : "Rib Direction", "Filter" : GeometryType.PLANE, "MaxNumberOfPicks" : 1 }definition.Plane is Query;annotation { "Name" : "Number of Ribs" }isInteger(definition.myCount, POSITIVE_COUNT_BOUNDS);annotation { "Name" : "Rib Thickness" }isLength(definition.myLength, LENGTH_BOUNDS);}{const p is Plane = evPlane(context, {"face" : definition.Plane});var b is Box3d = evBox3d(context, {"topology" : definition.Part,"cSys" : coordSystem(p)});const t is Transform = toWorld(coordSystem(p));b = box3d(t * b.minCorner, t * b.maxCorner);const line is Line = line(p.origin, p.normal);const p0 is Vector = project(line, b.minCorner);const p1 is Vector = project(line, b.maxCorner);const pl0 is Plane = plane(p0, p.normal);const pl1 is Plane = plane(p1, p.normal);opPlane(context, id + "pl0", {"plane" : pl0,});opPlane(context, id + "pl1", {"plane" : pl1,});});
 1